Aryaman Gupta

Hi, I’m Aryaman, a Ph.D. candidate at Stanford University, advised by Prof. Somil Bansal. I earned my B.Tech. in Electronics Engineering from IIT (BHU) Varanasi.
My research focuses on uncovering failure patterns in robotic systems to enable a continuous failure-guided improvement cycle. I aim to: (a) bake safety mechanisms into their design, and (b) ensure reliable operation at runtime through lightweight guardrails.
Grab my resume, or find my work on Google Scholar. Feel free to reach out — I’m always up for discussions on robotics and AI.
news
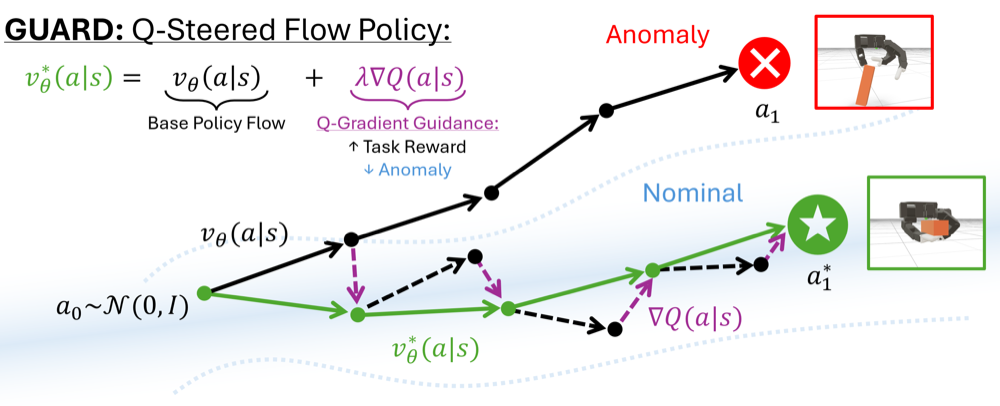
| Nov 2026 | New paper out on arXiv about combining dense anomaly signals with sparse task rewards to steer flow policies for robust dexterous manipulation. |
|---|---|
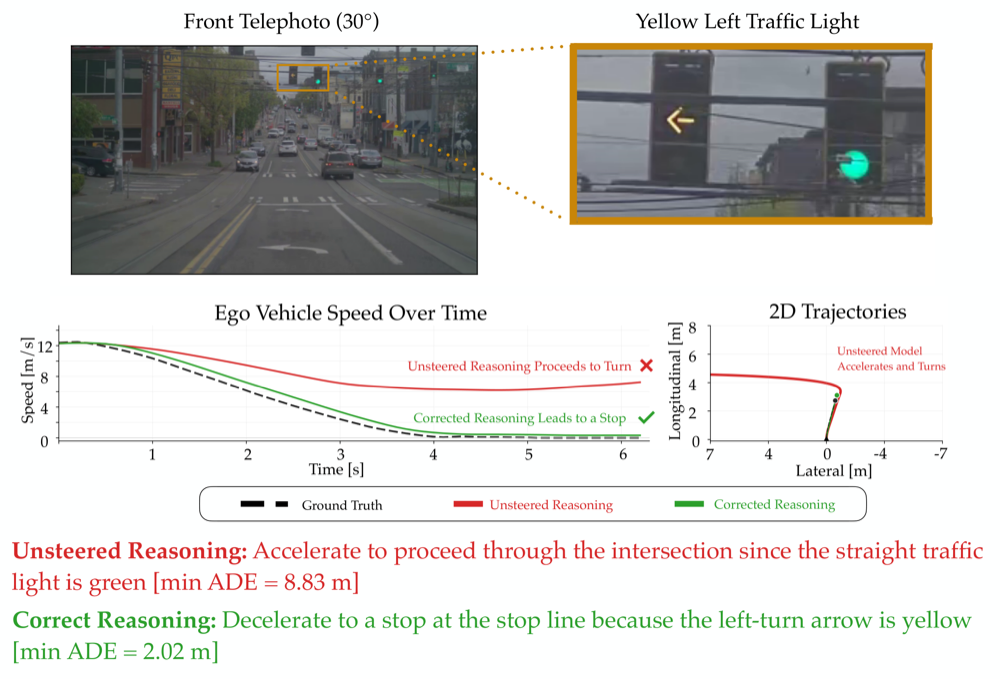
| Sep 2026 | New paper out on arXiv about monitoring and steering chain-of-thought reasoning in VLA policies. |
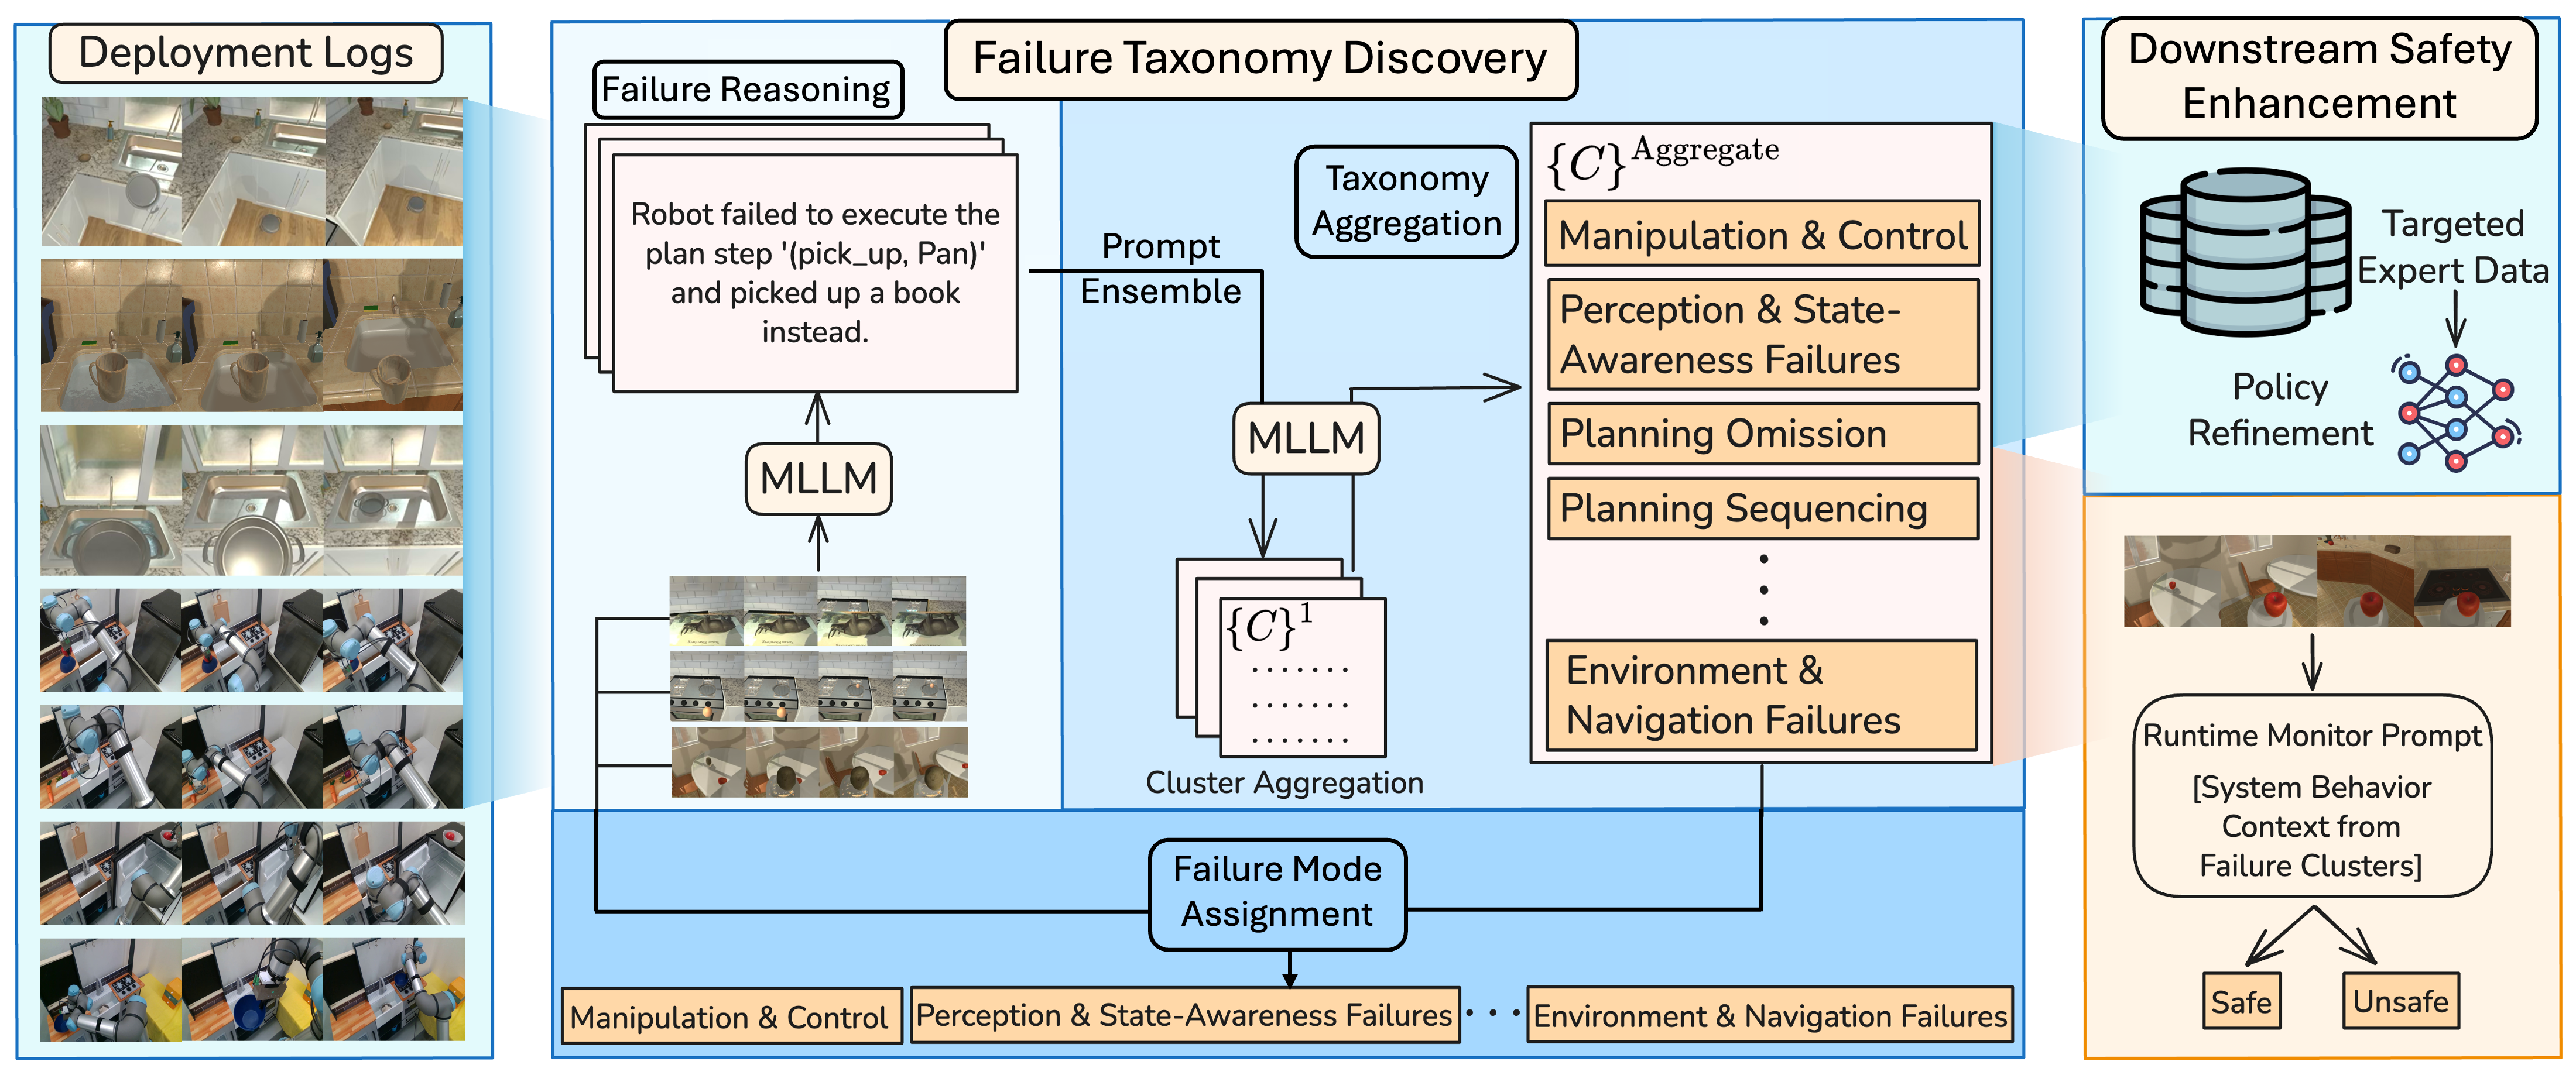
| Jun 2026 | My paper on discovering robot failure taxonomies got accepted into IROS 2026. |
| Jun 2026 | Starting my research internship at Honda Research Institute USA. |
| May 2026 | Passed my PhD qualifying exams! |
| May 2026 | My team won the Qualcomm Innovation Fellowship (North America) 2026. |